LuwuDynamicsWiki
/
LuwuDynamics
The XGO series Robot
  • ▾📁 Introduction & Ecosystem
    • XGO Philosophy
    • System Architecture
    • The XGO Ecosystem
    • XGO-lite3/mini2S
    • XGO-Rider2
    • XGO-mini2SW
    • XGO-Ranger
    • Plan
  • ▾📁 Luwu-OS User Manual
    • Luwu-OS User Manual
    • ▾📁 Operation Guide: On-Device Usage
      • Operation Guide: On-Device Usage
      • Chapter 1: Unboxing & Basic Operations
      • Chapter 2: Network Connection
      • Chapter 3: Remote Control & Video Streaming
      • Chapter 4: AI Conversation
      • Chapter 5: Vision Features
      • Chapter 6: Performance & Group Control
      • Chapter 7: Sensors
      • Chapter 8: Coding
    • ▾📁 development
      • Outline
      • Chapter 1 - Development Environment Setup
      • Chapter 2 - System Architecture
      • Chapter 3 - Application Development
      • Chapter 4 - xgolib Robot Control
      • Chapter 5 - MQTT Communication
      • Chapter 6 - AI Model Replacement
  • ▾📁 Software Development
    • XGO Serial Protocol
    • ▾📁 XGO Python Library
      • xgolib_dog
      • xgolib_rider
  • ▾📁 Resources & Downloads
    • Design Files
  • ▾📁 ROS
    • ROS
  • ▾📁 Reinforcement Learning
    • Reinforcement Learning
  • About Luwu Dynamics
  • Upgrade Guide
Contents
The XGO series Robot

The XGO series Robot

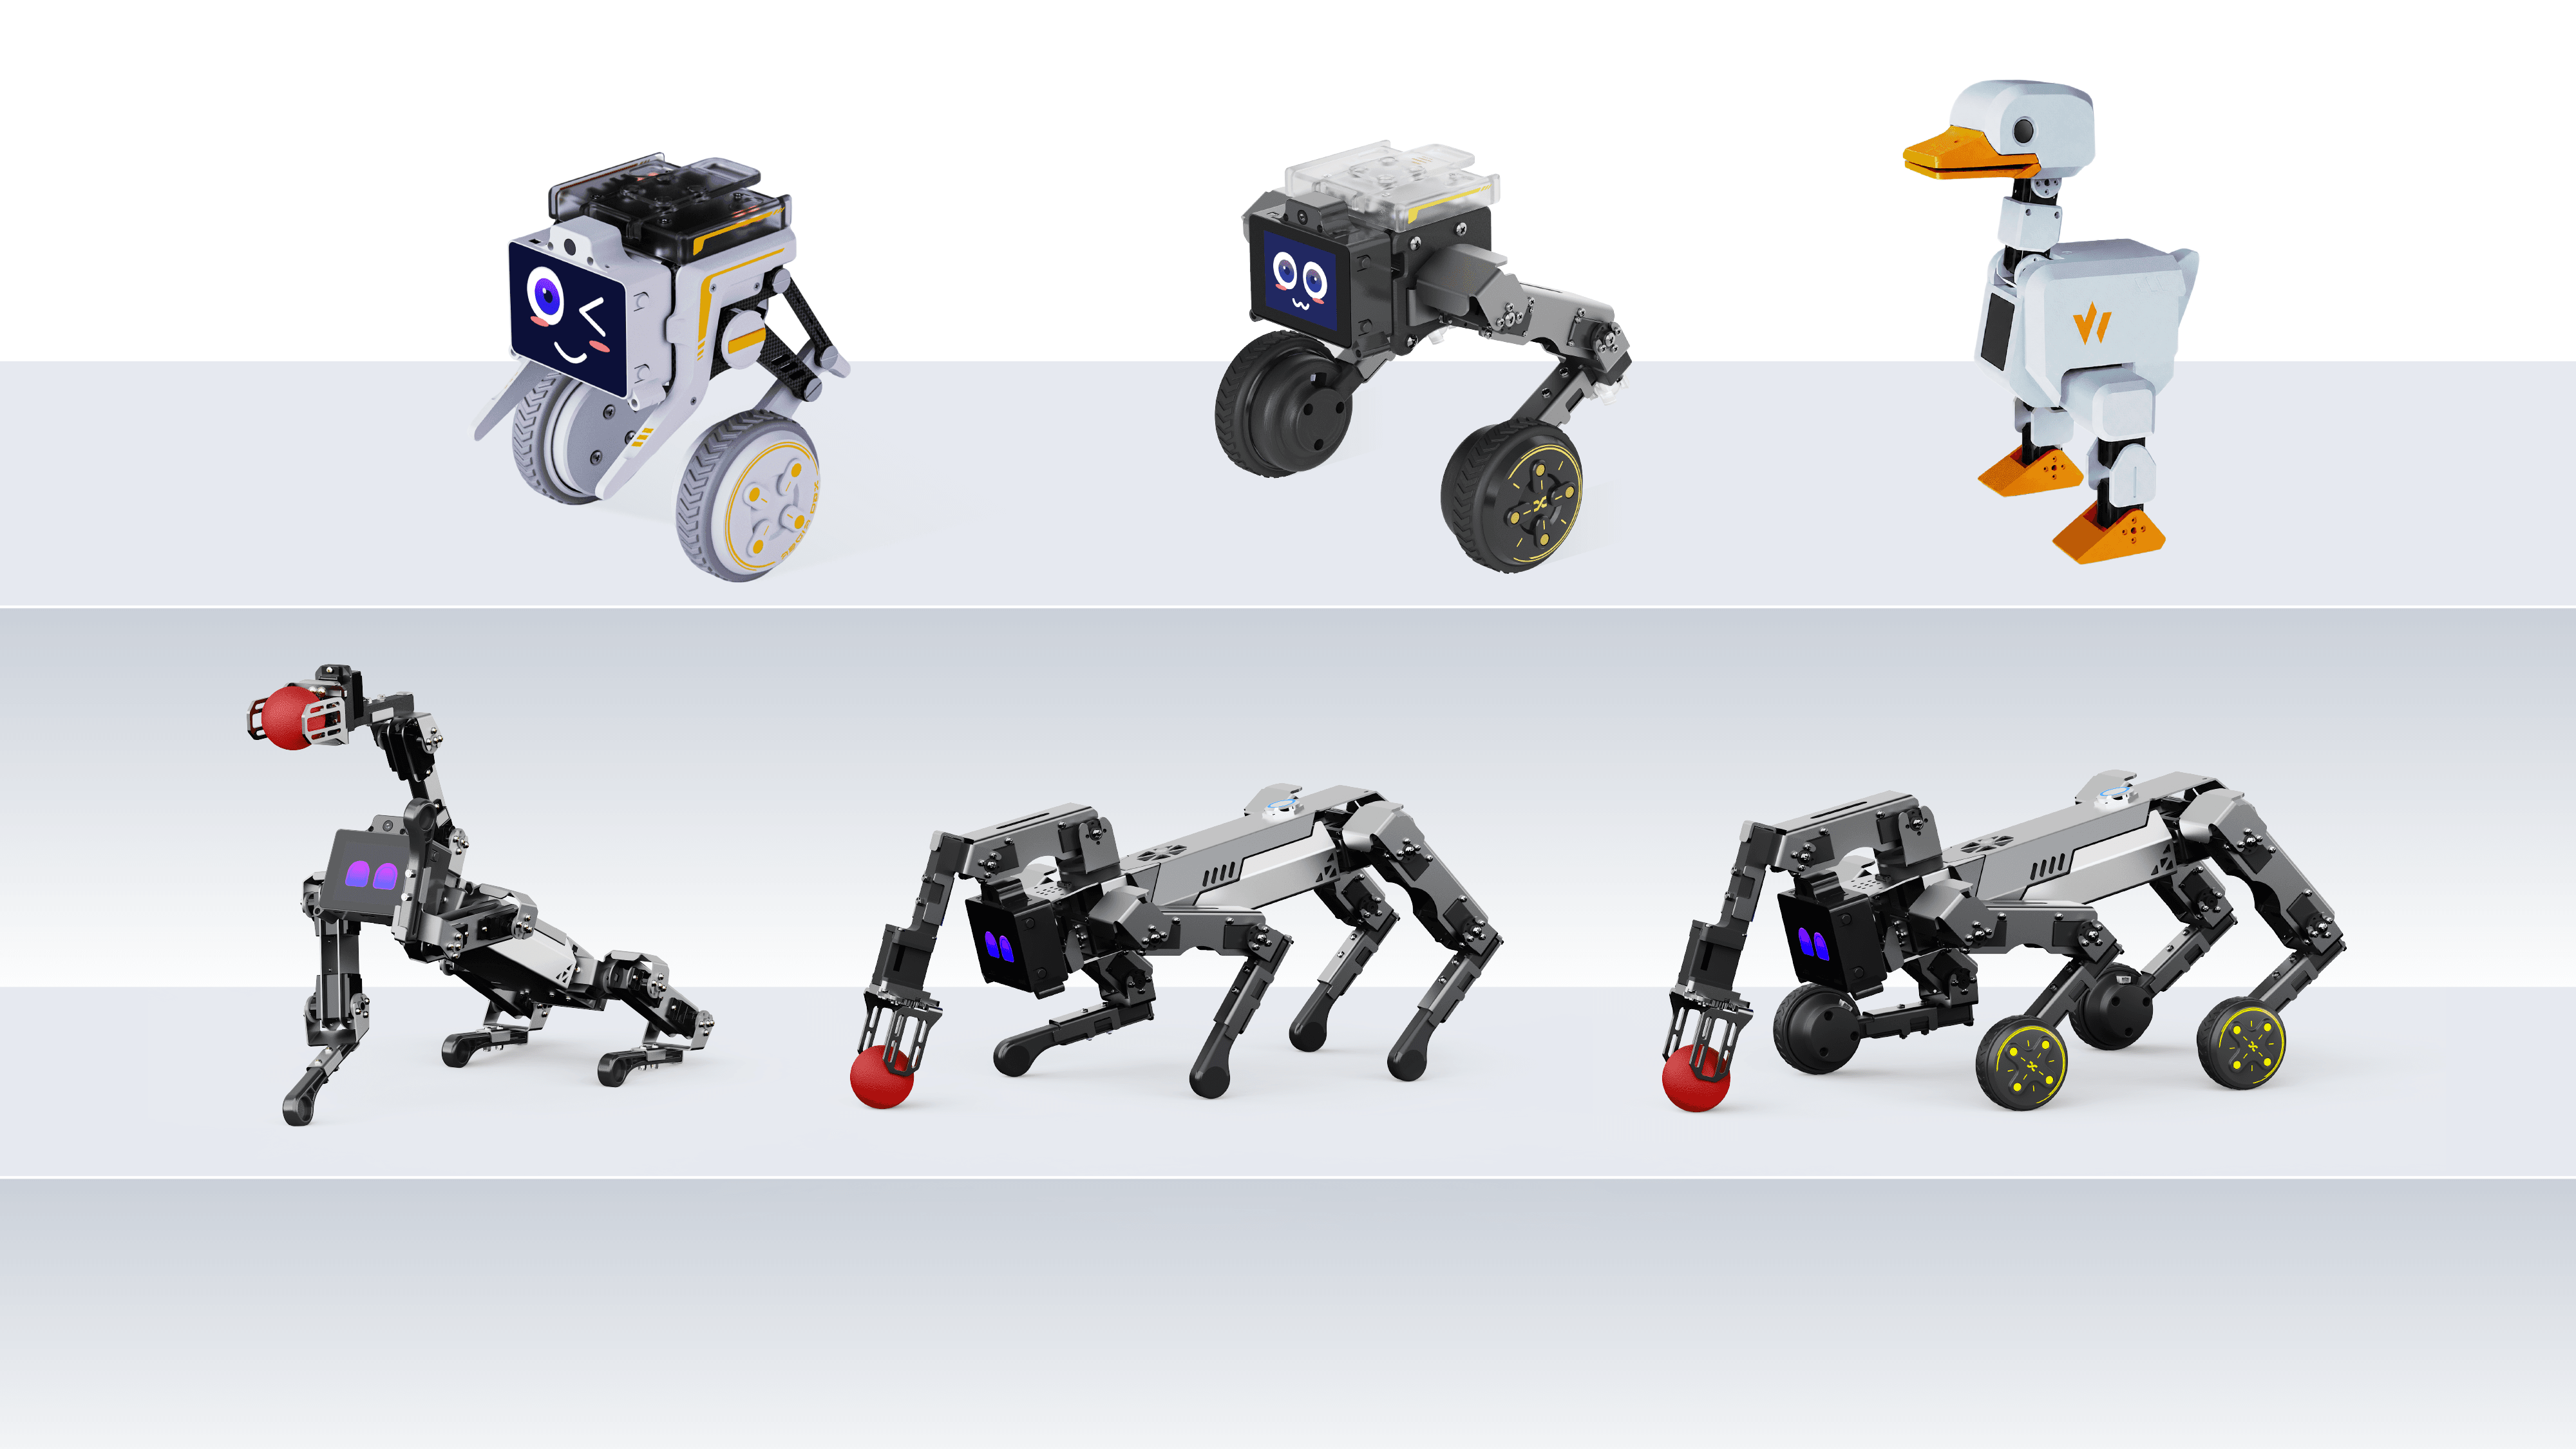
The XGO series is an open-source desktop robotic platform designed to bridge the gap between educational toys and industrial research robots.

Start Reading →

📑 Documents 33 docs

    Introduction & Ecosystem8
    XGO PhilosophySystem ArchitectureThe XGO EcosystemXGO-lite3/mini2SXGO-Rider2XGO-mini2SWXGO-RangerPlan
    Luwu-OS User Manual3
    Luwu-OS User Manual
    Operation Guide: On-Device Usage9
    Operation Guide: On-Device UsageChapter 1: Unboxing & Basic OperationsChapter 2: Network ConnectionChapter 3: Remote Control & Video StreamingChapter 4: AI ConversationChapter 5: Vision FeaturesChapter 6: Performance & Group ControlChapter 7: SensorsChapter 8: Coding
    development7
    OutlineChapter 1 - Development Environment SetupChapter 2 - System ArchitectureChapter 3 - Application DevelopmentChapter 4 - xgolib Robot ControlChapter 5 - MQTT CommunicationChapter 6 - AI Model Replacement
    Software Development2
    XGO Serial Protocol
    XGO Python Library2
    xgolib_dogxgolib_rider
    Resources & Downloads1
    Design Files
    ROS 1
    ROS
    Reinforcement Learning1
    Reinforcement Learning
    About Luwu DynamicsUpgrade Guide
© 2026 Luwu Intelligence (XGoRobot). All rights reserved.
Official SiteContact