陆吾智能Wiki
/
陆吾智能
The XGO series Robot
  • ▾📁 Introduction & Ecosystem
    • XGO Philosophy
    • System Architecture
    • The XGO Ecosystem
    • XGO-lite3/mini2S
    • XGO-Rider2
    • XGO-mini2SW
    • XGO-Ranger
    • Plan
  • ▾📁 Luwu-OS User Manual
    • Luwu-OS User Manual
    • ▾📁 Operation Guide: On-Device Usage
      • Operation Guide: On-Device Usage
      • Chapter 1: Unboxing & Basic Operations
      • Chapter 2: Network Connection
      • Chapter 3: Remote Control & Video Streaming
      • Chapter 4: AI Conversation
      • Chapter 5: Vision Features
      • Chapter 6: Performance & Group Control
      • Chapter 7: Sensors
      • Chapter 8: Coding
    • ▾📁 development
      • Outline
      • Chapter 1 - Development Environment Setup
      • Chapter 2 - System Architecture
      • Chapter 3 - Application Development
      • Chapter 4 - xgolib Robot Control
      • Chapter 5 - MQTT Communication
      • Chapter 6 - AI Model Replacement
  • ▾📁 Software Development
    • XGO Serial Protocol
    • ▾📁 XGO Python Library
      • xgolib_dog
      • xgolib_rider
  • ▾📁 Resources & Downloads
    • Design Files
  • ▾📁 ROS
    • ROS
  • ▾📁 Reinforcement Learning
    • Reinforcement Learning
  • About Luwu Dynamics
  • Upgrade Guide
The XGO series RobotIntroduction & EcosystemPlan

Plan

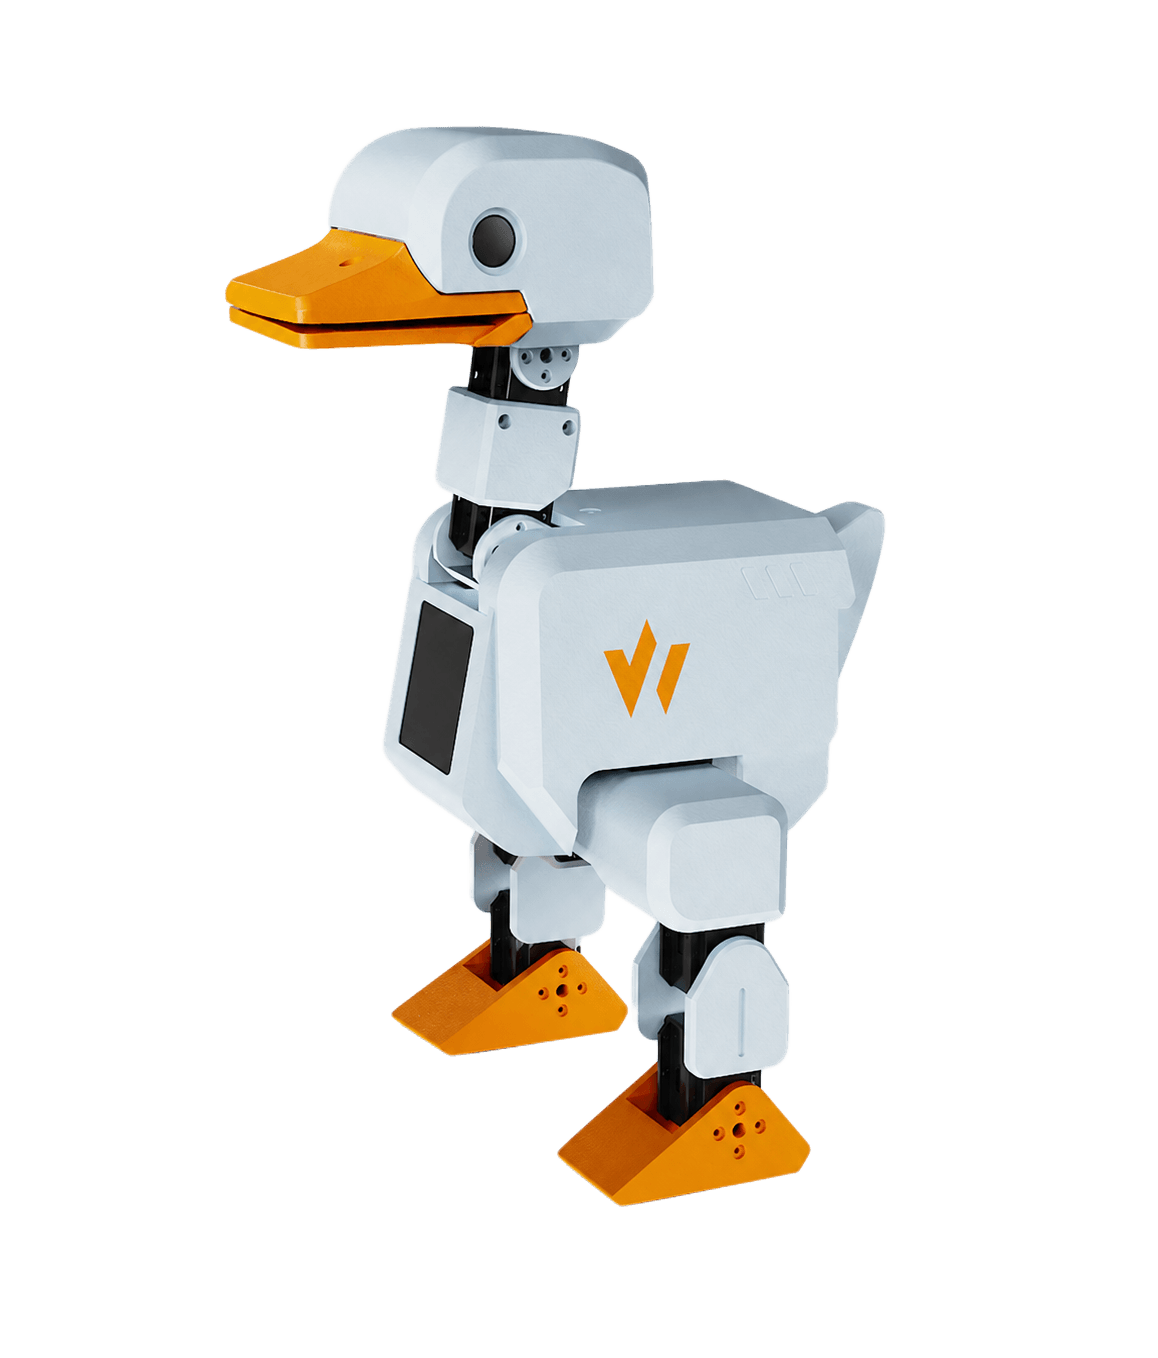
XGO-Duck

duck.png

XGO-Switch

最后更新于 2026/8/25 18:27:08
上一篇XGO-Ranger下一篇Luwu-OS User Manual

相关文档

📄XGO Philosophy2026年10月14日📄System Architecture2026年10月14日📄The XGO Ecosystem2026年10月14日📄XGO-lite3/mini2S2026年10月14日📄XGO-Rider22026年10月14日📄XGO-mini2SW2026年10月14日
© 2026 陆吾智能(XGoRobot)保留所有权利
官网联系我们